Engineering note / 4 October 2026
Start with the controller and interface
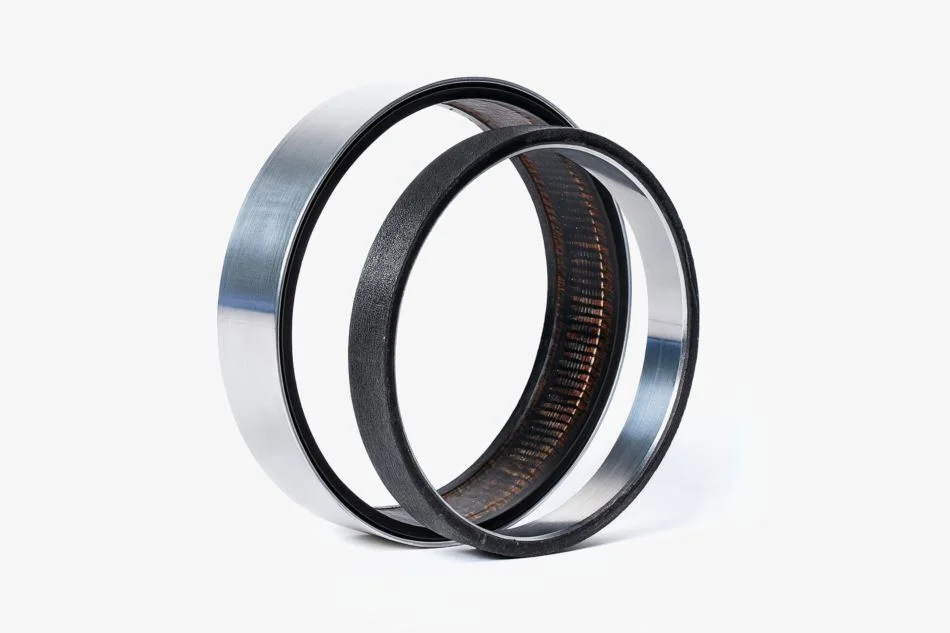
Name the controller and state the required electrical interface. FLUX documents absolute BiSS/C and SSI options and incremental A/B/Z options for GMI-ROTARY. Select a supported ordering configuration with FLUX; these interfaces are not interchangeable descriptions of the sensing technology.
Describe the mounting geometry
Provide the available envelope, shaft or bore arrangement and the proposed rotor and stator attachment. Identify alignment references, cable routing and access for assembly. Include a drawing revision and explain where the standard arrangement does not fit.
State the operating conditions
List temperature, contamination, vibration and electrical-noise conditions as requirements. FLUX lists IP67 for GMI-ROTARY; verify the selected model and installation conditions. Do not apply that rating to every encoder family or to the complete machine.
Include volume and project timing
Give the prototype quantity, expected annual demand and design-review timing. Explain which features require customization and which could remain standard. Feasibility, minimum volume, tooling and delivery scope need manufacturer confirmation.
This note helps prepare a technical brief. Product performance and application suitability require project-specific confirmation.
Manufacturer reference: FLUX GMI-ROTARY datasheet, revision 03